
Joint Modules
J60 Series Robot Joints
Integrated Joint Module
Model:J60-6 / J60-10
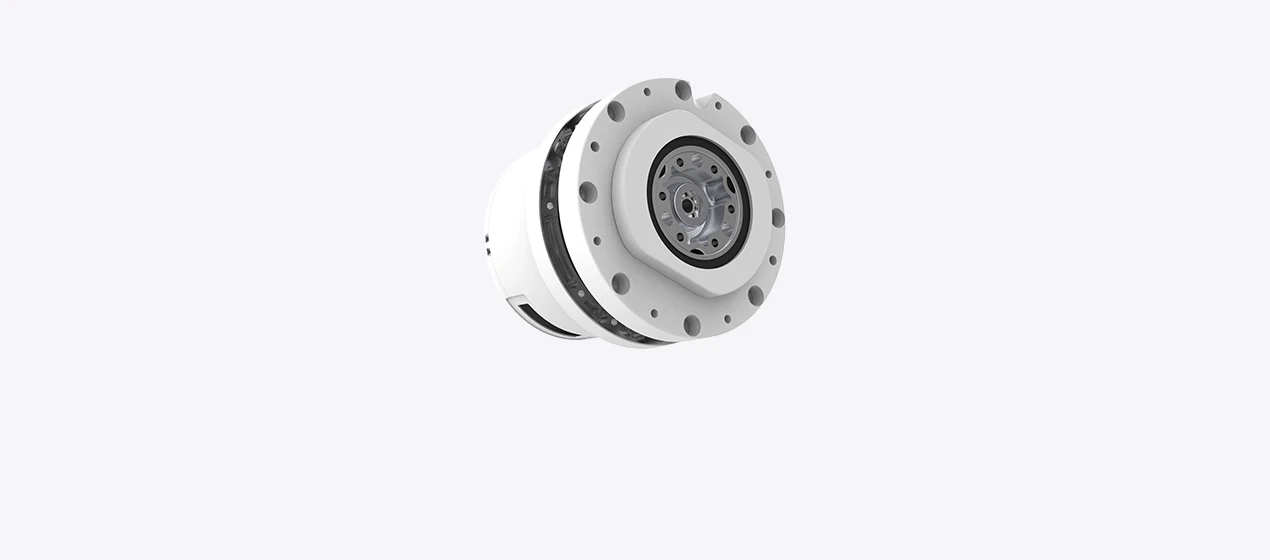
Integrates a gearbox, frameless torque motor, servo drive, and encoder into one unit.
The J60 series is an integrated robotic joint module combining a reducer, frameless torque motor, servo driver, and absolute encoder. The J60-10 delivers a peak torque of 30.50Nm Nm and a torque-to-weight ratio of 56.48Nm/kg, making it ideal for model-based and learning-based control in legged robots. It has been mass-deployed on the Jueying Lite3 platform.
Features
Product Features
Integrates a gearbox, frameless torque motor, servo drive, and encoder into one unit.
Superior Performance
Outstanding torque performance for its weight class. The J60-10 delivers a peak torque-to-weight ratio of 56.48Nm/kg.
Reliable and Durable
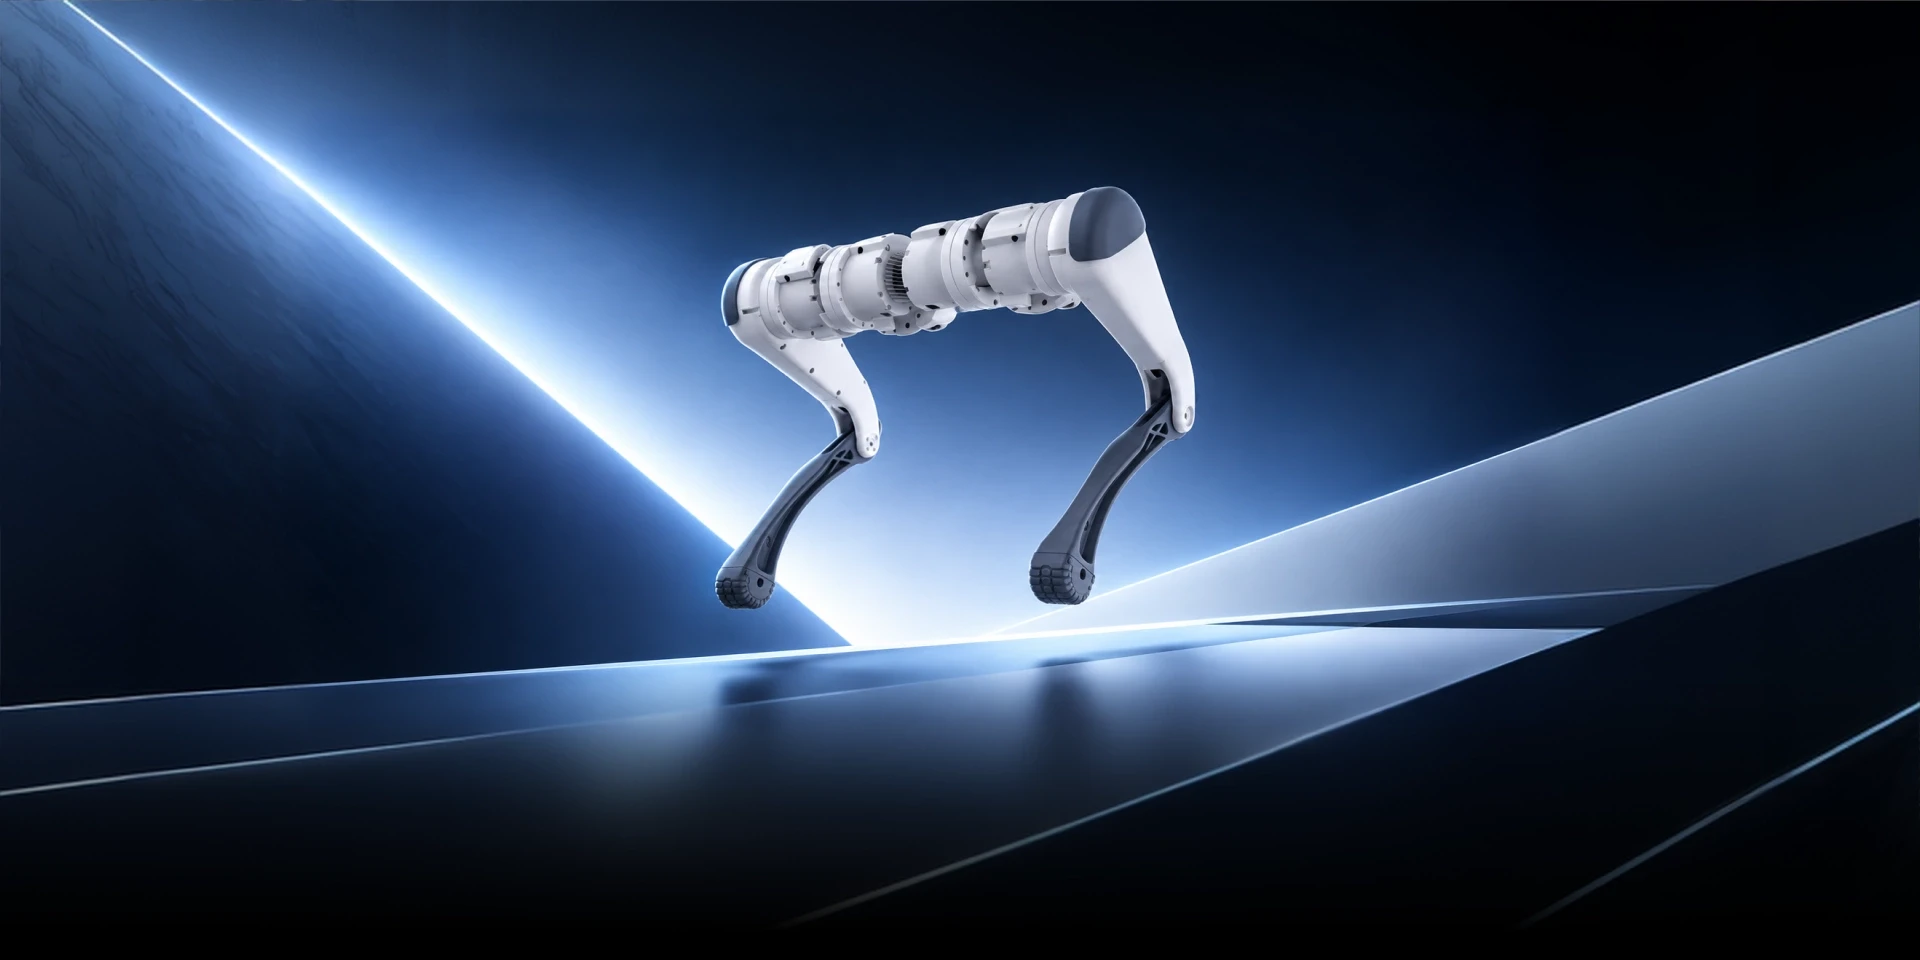
Supports model-based control and learning-based control for legged robots; already deployed in mass production for the Jueying Lite3.
Integrated design
Integrates a gearbox, frameless torque motor, servo drive, and absolute encoder into a compact, easy-to-install unit.
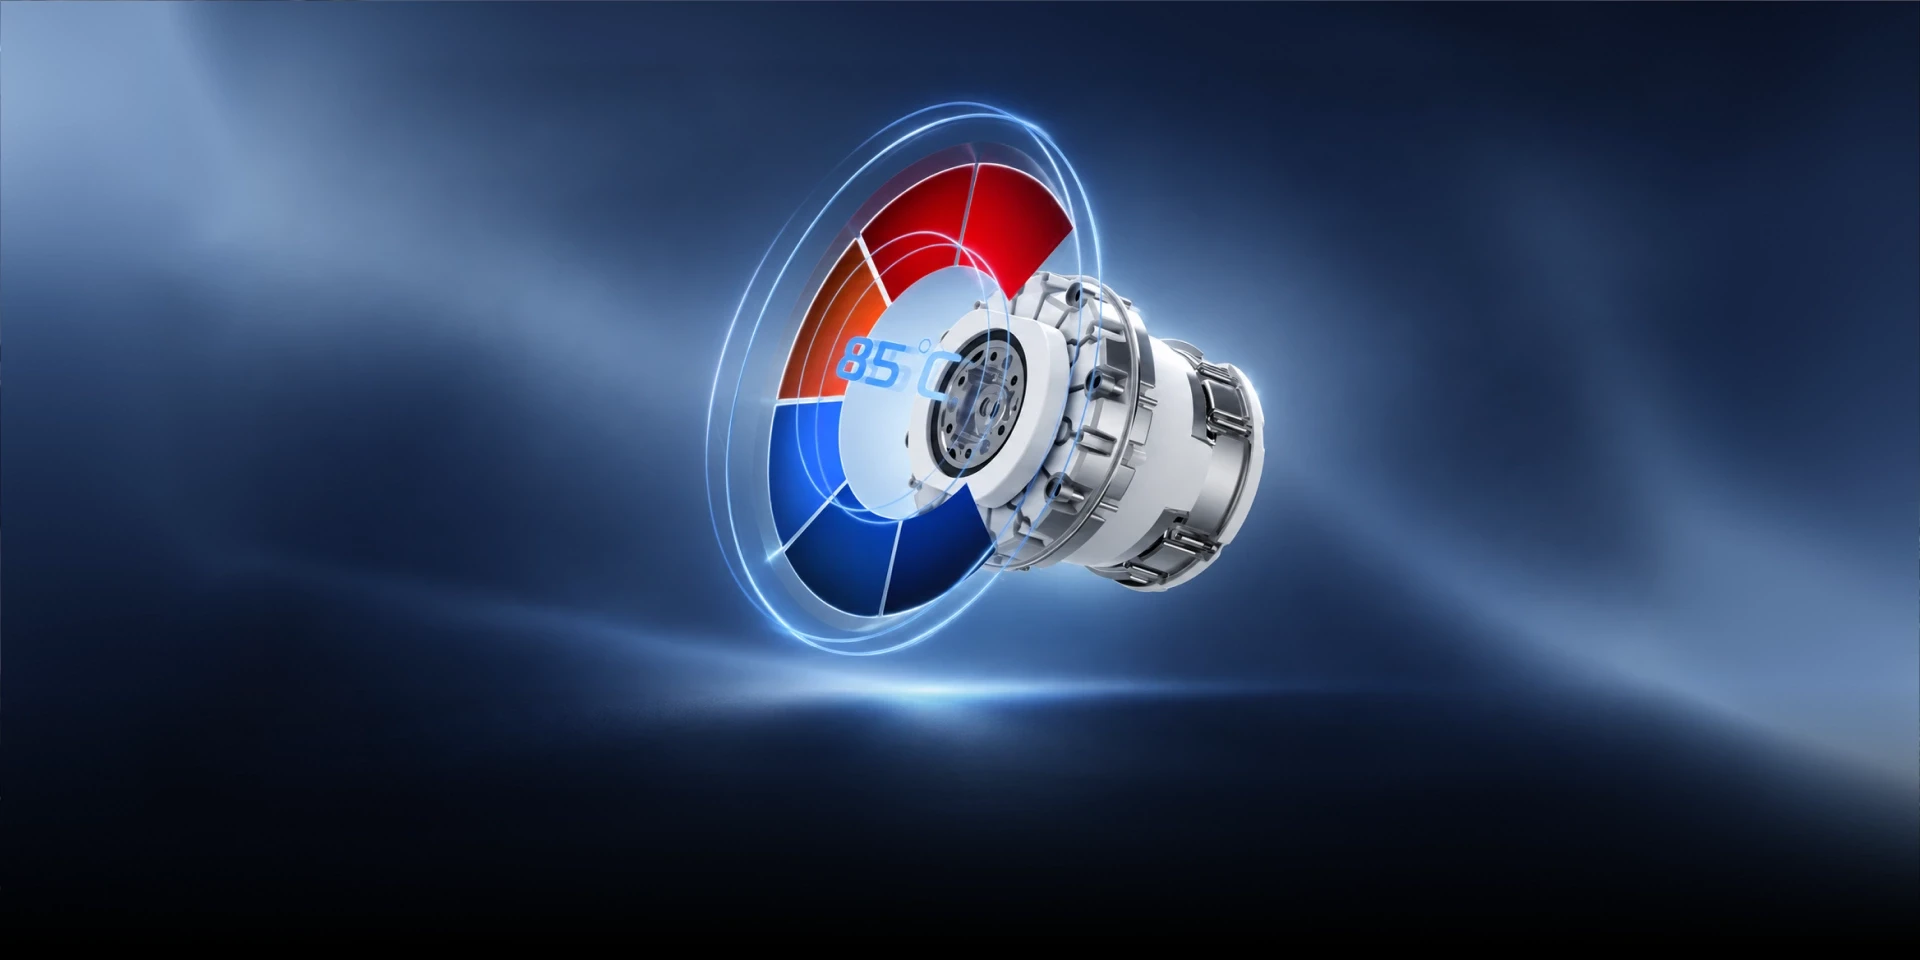
Status Monitoring and Protection
Built-in temperature detection and protection system that monitors input current and voltage in real time for safer joint operation.
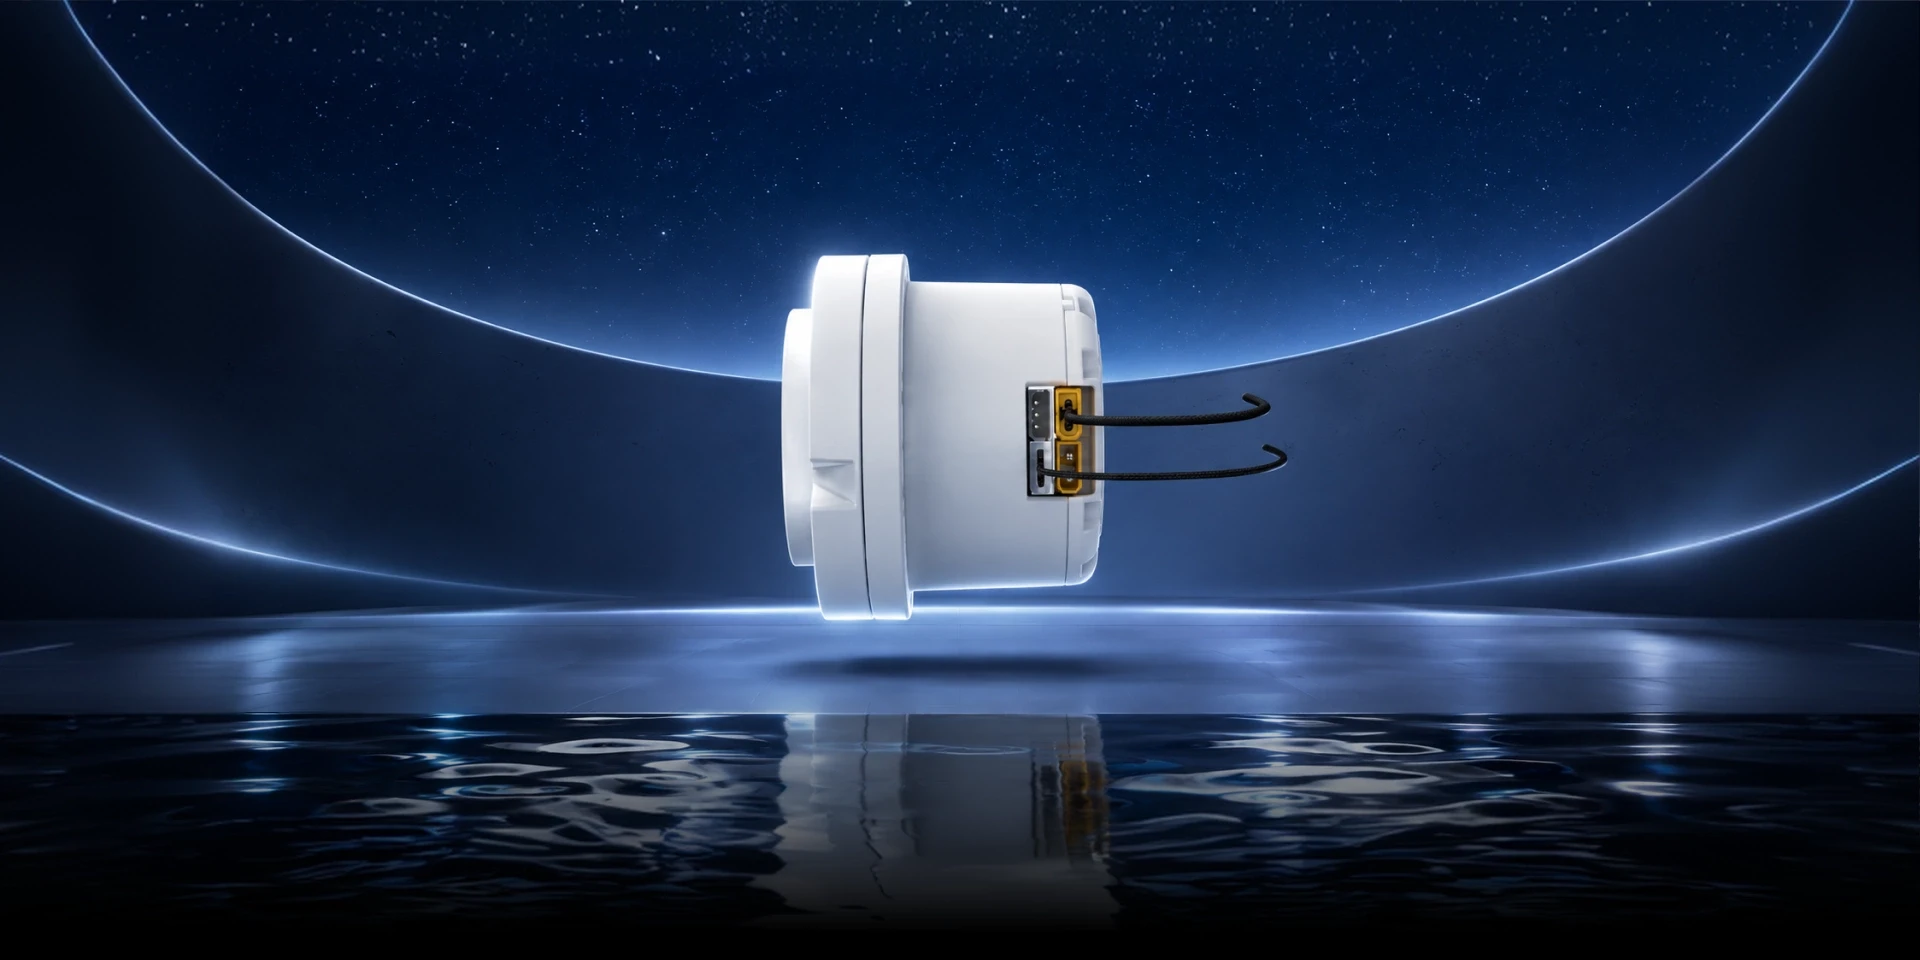
Debug & Development Kit
Equipped with serial and CAN communication interfaces, it offers a visual joint debugging tool. Supports Windows and Linux systems along with C language SDKs and example code.
Specifications
Product Specifications
Product specifications are entered based on the official Deep Robotics website and can be viewed with version-based differences.
Specifications
| Size | 76.5mm * 63mm |
|---|---|
| Total Weight | 480g |
Voltage and Current
| Operating Voltage Range | DC 18V~36V |
|---|---|
| Standard Operating Voltage | DC 24V |
| Motor Maximum Phase Current | 30A |
Torque
| Peak torque | 19.94Nm |
|---|---|
| Peak RPM | 24.18rad/s |
| Joint Torque Constant | 0.8982Nm/A |
| Torque-to-weight ratio | 41.54Nm/kg |
Encoder
| Encoder Type | Absolute Encoder |
|---|---|
| Encoder Resolution | 14-bit |
Communication
| Communication Method | CAN |
|---|---|
| Communication Baud Rate | 1 Mbps |
| Communication Control Frequency | 1kHz |
The product performance, features, and specifications displayed on this page are sourced from the official Deep Robotics website and represent laboratory test results. They are provided for informational purposes only and do not constitute a delivery commitment. Final product configuration and performance metrics shall be governed by the contract agreement between both parties and the delivered physical units. Products will undergo continuous iteration and optimization; any adjustments to technical parameters shall be based on the latest documentation.
[1] This is extreme test data from a lab environment. For security reasons, the testing methodology is not disclosed to the public.
Other products in the same category
Submit Purchase Intent
Enter the model, quantity, and use case. A sales consultant will confirm the version configuration, delivery timeline, and supporting services with you.
- Current Model:J60 Series Robot Joints(J60-6)
- Category:Joint Component
- Parameter Description:The product performance, features, and specifications displayed on this page are sourced from the official CloudDeep Technology website and were measured in a laboratory environment.…
Purchase Intent
Submit your requirements and contact details. A sales consultant will confirm pricing, stock availability, and delivery options with you. Product prices are subject to quotation.